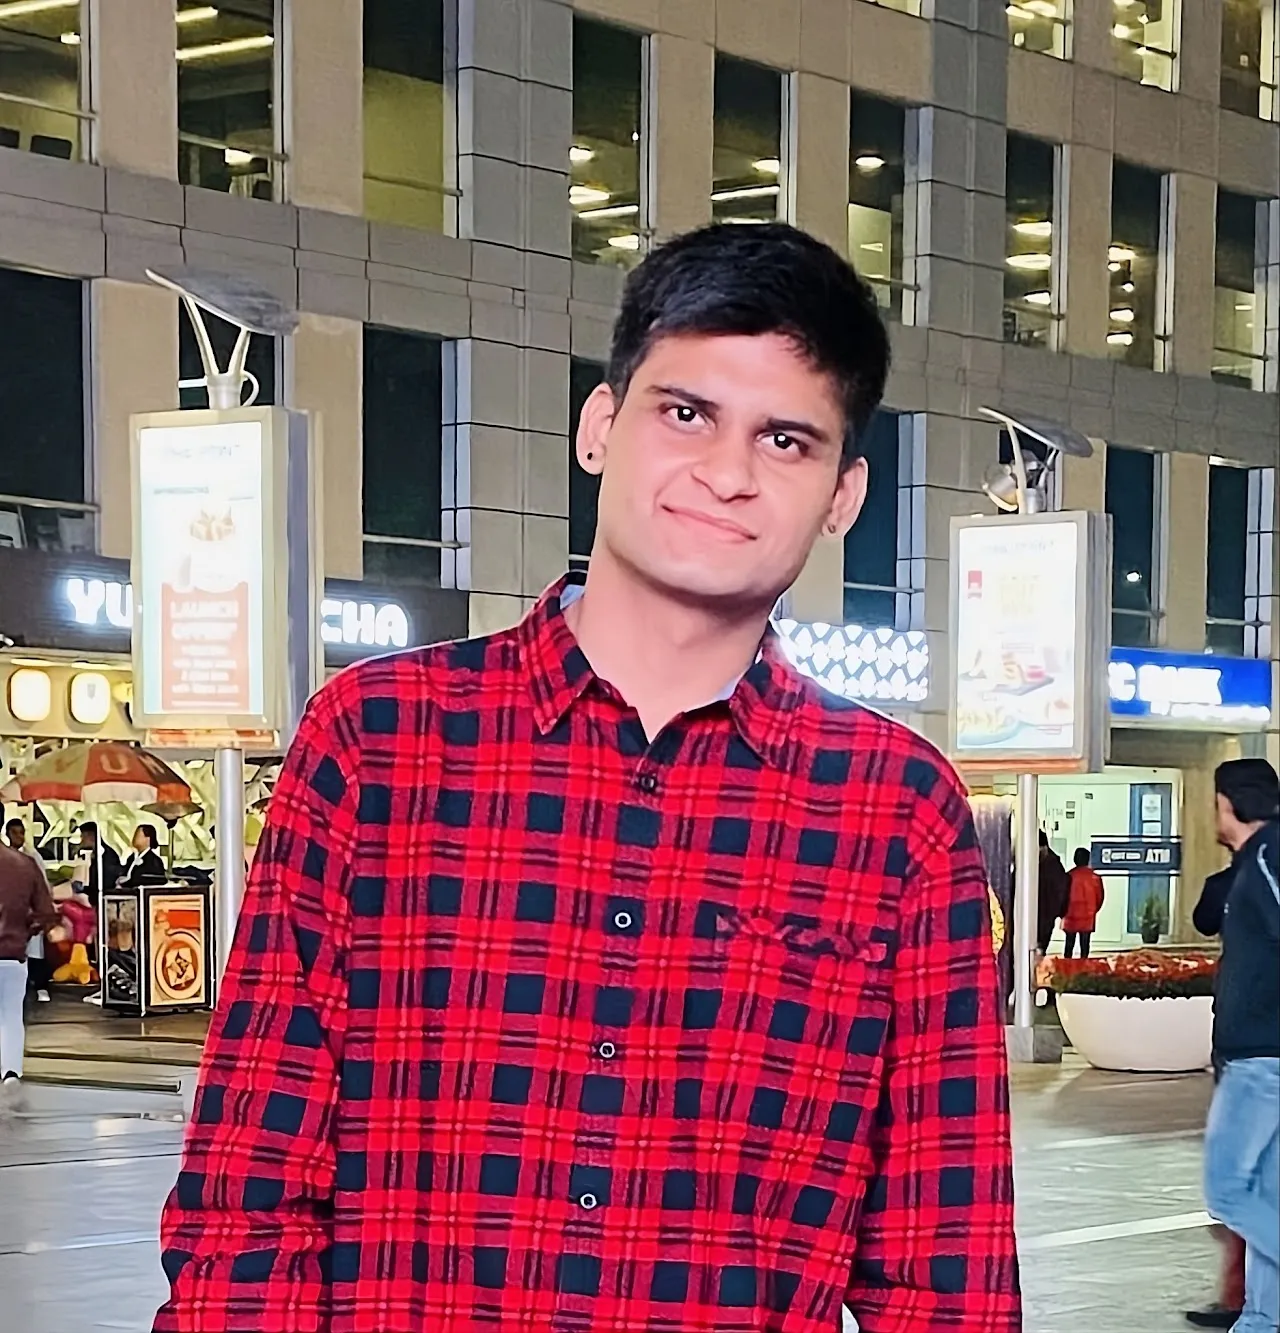
Siddharth Mishra
Data Scientist at Deepmatrix, working on Spatial AI — LiDAR and photogrammetry point-cloud segmentation, and geospatial object detection. Moving toward robotics.
Research interests
Primary focus · Robotics
Robotics is where I'm heading next. My work so far has been on the perception side — getting models to understand 3D scenes from LiDAR, photogrammetry and aerial imagery. What I want to learn is the rest of the loop: running that perception on real hardware, inside a robot's compute and latency budget, and using it to drive decisions that move something in the physical world.
3D perception for robots
Scene understanding a robot can act on — segmenting and parsing point clouds from onboard LiDAR and depth sensors as the robot moves, rather than from offline survey scans.
From my work: End-to-end LiDAR and photogrammetry semantic segmentation pipelines; a custom PointNet-EdgeConv based model, plus RandLA-Net and Point Transformer V3, reaching up to 89% mIoU on large-scale infrastructure datasets.
Perception on real hardware
Fitting perception into the latency and compute budget of an onboard computer, where every millisecond of inference competes with control.
From my work: Optimized voxel sampling (FPS, Morton code) for large point clouds, and a two-stage YOLOv5 pipeline with multithreaded optimization for production use.
State estimation
Inferring the hidden state of a physical system from noisy, time-varying sensor signals — the problem underneath localization, sensor fusion, and battery management on mobile robots.
From my work: Real-time state-of-charge estimation for EV batteries using driving pattern synchronized neural networks (IEEE DECoN 2025), on top of a B.Tech in Electrical Engineering.
Perception that generalizes
Recognizing unfamiliar objects from a handful of examples — what a robot needs once it leaves a fixed, pre-labeled environment.
From my work: An INSID3 & DINOv3-based few-shot detection system for satellite, orthomosaic, and SAR imagery.
Recent news
TODO(sid): replace this entry with your latest news. Delete it once you add a real item — it renders on the homepage as-is.
Paper on real-time state-of-charge estimation for EV batteries presented at IEEE DECoN 2025. DOI
Released YOLOv11 from scratch — a clean-room PyTorch implementation built for easy customisation. Code
Joined Deepmatrix Private Limited as a Data Scientist, working on geospatial computer vision.
Graduated from IIT (ISM) Dhanbad with a B.Tech in Electrical Engineering.
Ranked top 10 of 3000+ teams in Fibe: Hack the Vibe! 2.0 text classification challenge.
Second runner-up (top 3 of 6375 teams) at Rakathon 2024, Rakuten India's 24-hour competition, for Rakumon. Code
Honorable Mention in the PyTorch Docathon 2023 for open-source docstring contributions.
About
I'm a Data Scientist at Deepmatrix Private Limited, where I build geospatial computer vision systems. Day to day that means end-to-end semantic segmentation pipelines for LiDAR and photogrammetry point clouds, oriented bounding-box detection for power-line and cell-tower defects, and few-shot detection across satellite, orthomosaic and SAR imagery.
I graduated from the Indian Institute of Technology (Indian School of Mines) Dhanbad in May 2025 with a B.Tech in Electrical Engineering (CGPA 8.68). Before that I was an AI/ML intern at Deepmatrix, working on orthomosaic segmentation and GIS automation.
I also like building things from first principles — reimplementing YOLOv11 and a decoder-only transformer from scratch, mostly to understand what the abstractions are hiding.
Publications
Gunjan Haldar, Siddharth Mishra
Real-Time State-Of-Charge Estimation for Electric Vehicle Batteries Using Driving Pattern Synchronized Neural Networks
2025 International Conference on Data, Energy and Communication Networks (DECoN), 2025.
DOI: 10.1109/DECoN67170.2025.11447768